dum·e A WORKING NOTEBOOK
EMBEDDED CONTROL · ROS 2 · AUTONOMY

A small robot.
A lot to figure out.

dum-e is my test bench for robots that can do a little more on their own.

Motor control, sensing, mapping and autonomous behaviors. Built on the bench, tried in simulation, and documented with the measurements that make the result worth sharing.

Read the latest experiment ↓
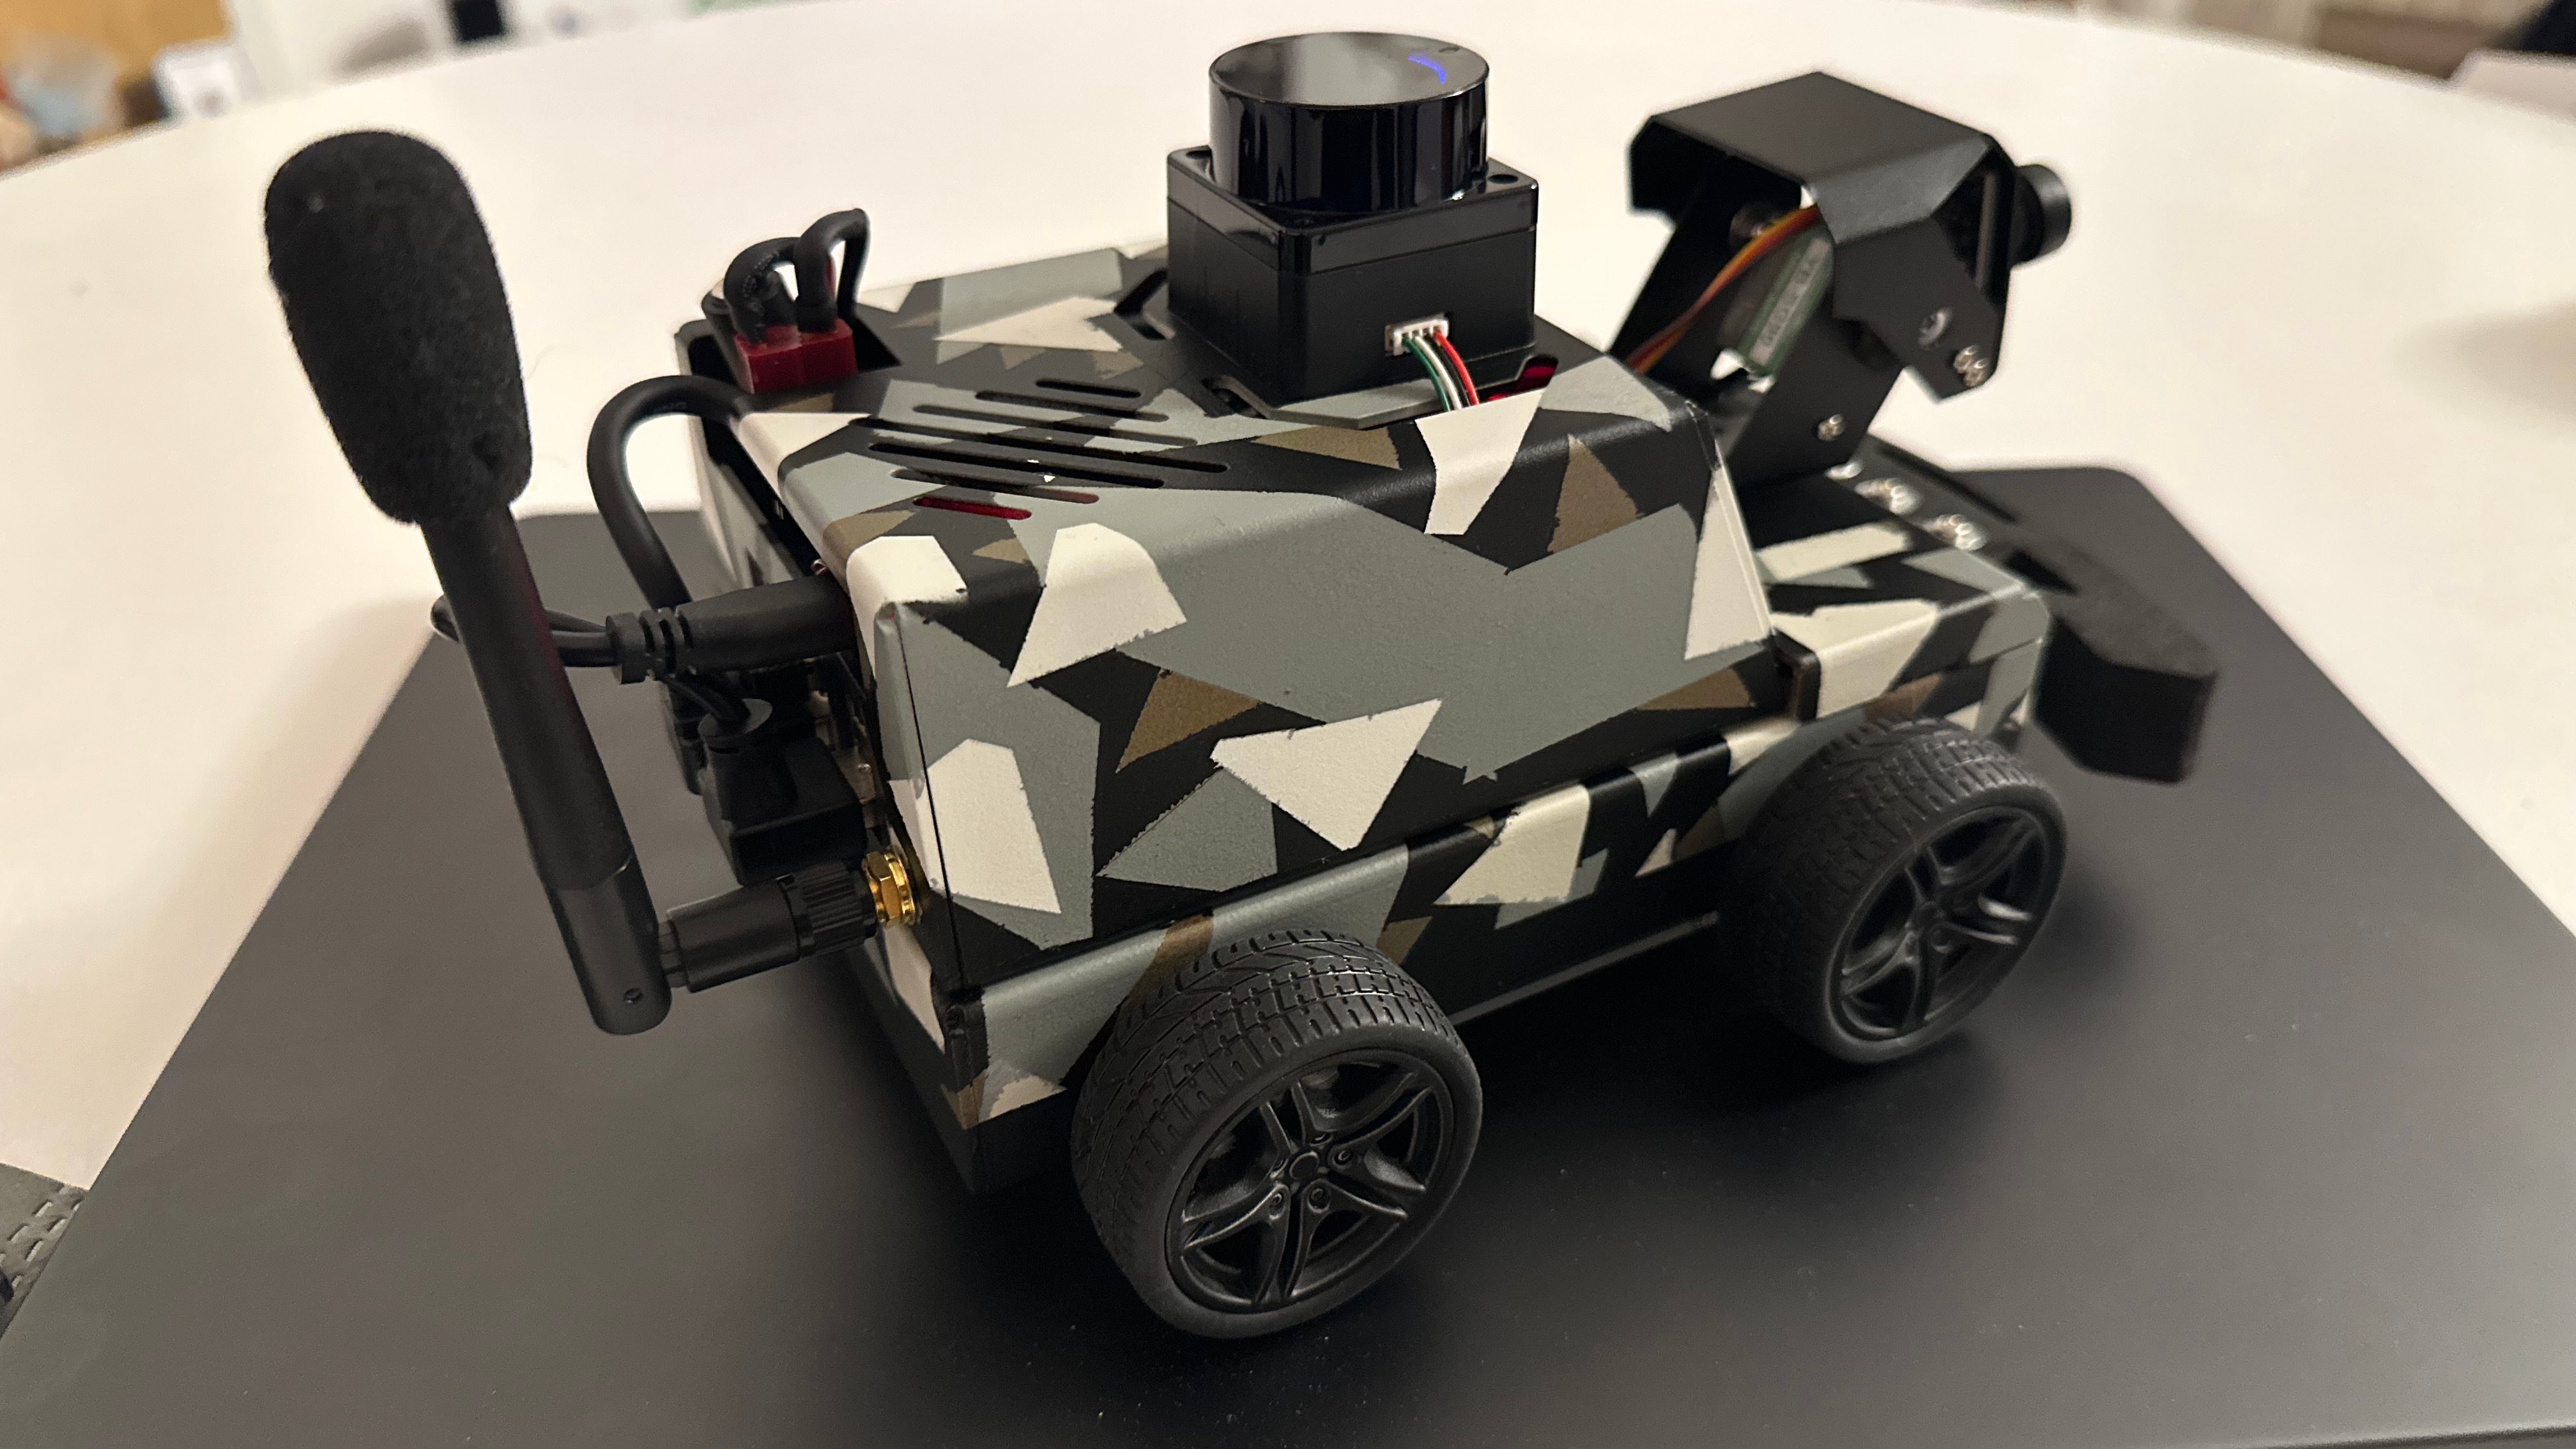
The real dum-e robot on the workbench, with its camouflage body, lidar and camera gimbal
dum-e, on the bench. The physical robot behind the experiments.
THE PROJECT

From wheel commands
to autonomous behavior.

The aim is a robot that can explore, understand enough of its surroundings to act, and make useful decisions onboard. ROS 2 connects the pieces; simulation provides a place to test them before the hardware does.

This notebook follows that work as it happens: controller experiments, integration details, tools and the occasional fix needed along the way. Each study keeps its code, method and evidence close together.

LATEST FROM THE BENCH

One experiment at a time.

01 / NOVEMBER 2026
SIMULATION STUDY · 7 NOV 2026

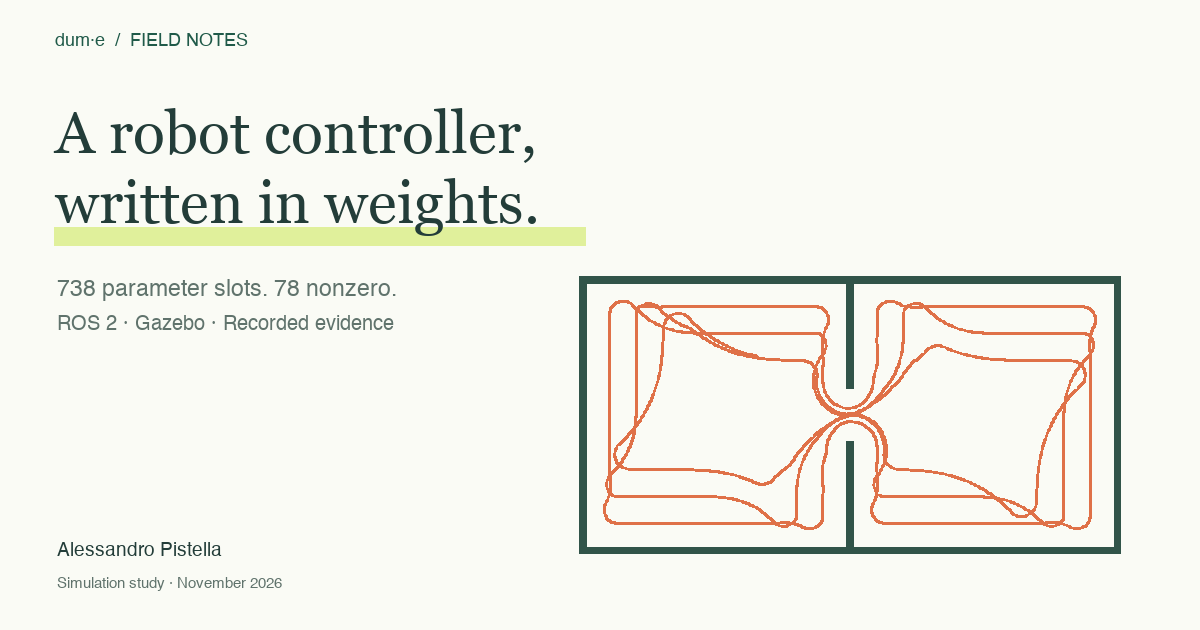
A robot controller,
written in weights.

Could a tiny neural network steer a robot using weights written directly by an AI? Two rooms, one doorway and a lidar make the question concrete. Recorded runs and a comparison of architectures show what it can do.

Read the experiment ↗